CoCoMaps at CES 2017
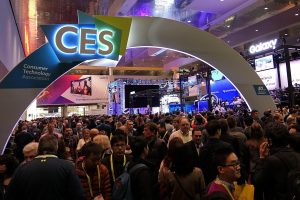 The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems.
The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform. Share:LinkedInXEmail Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems. Download PsycloneExplore Psyclone AIOSTalk to us…
The stage has now been set for our robots to show off their capabilities so far. The robots are to map out an area which they scan for humans using search patterns. Each human detected will be identified using facial recognition. All information is instantly shared with the other robot via the CCMCatalog. Let’s see…
Although Siri can be quite helpful and at times pleasant to communicate with she still lacks the flexibility of a human duologue partner making conversing with her have an unnatural flow. In fact Siri – like other robots – is lacking in her turn taking ability. To communicate somewhat smoothly with robots one needs to…
Psyclone 2.0.3 has been released on the Download page which now includes a freshly written System Reference doc and the new CMSDK documentation site. Read more about some of the many Psyclone platform use cases. Share:LinkedInXEmail Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems. Download PsycloneExplore Psyclone AIOSTalk to us More…
Preparation of our robots is now in full swing to get them up and running for our first demo. The on-board cameras all need to run at the same time which we have been testing as well as getting the robots to communicate through the CCMCatalog. The first trial run went pretty well but afterwards…
Demo 1 produced a lot of data and we are working our way through it now. Preliminary figures suggest that the CCMCatalog enabled the robots to collaborate far more efficiently when working together and that the robots were able to detect and track humans in the scene. Stay tuned for more results… Share:LinkedInXEmail Published…