CoCoMaps invited to exhibit at Hannover Messe 2017
 The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform.
The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform.
Psyclone 2.0 already supports user authored native C++ modules running in a mixed Windows/Linux cluster environment. Now we have added native Python 2.7 and 3.5 support so our users can create either inline or separate modules written entirely in Python. As part of the CoCoMaps project we are now integrating with ROS (Robot Operating System)…
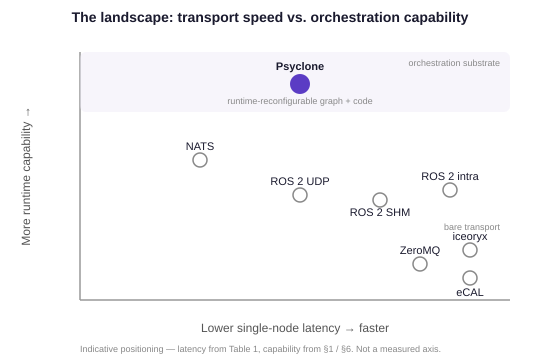
A rigorous single-node latency benchmark of Psyclone AIOS against NATS, ROS 2, iceoryx, eCAL and ZeroMQ – competitive default speed, the tightest tails measured, and the runtime-reconfiguration capabilities that set it apart.
A joint proposal by CMLabs and IIIM for the project CoCoMaps has been accepted by the ECHORD++ EU consortium for funding starting from September 2016.
The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
Today the CoCoMaps project officially launched! We are very exited to set off on this journey after months of preparation. The aim of the project is to endow robots with the skills to communicate with humans in real time using natural dialogue. If successful these improved communicational skills of the robots will enable much more sophisticated…
Ever tried conversing with a robot on the other end of a telephone customer service line? Now try adding a slight delay due to indeterminism and prepare for a frustrating interruption followed by a back and forth between incorrect options, cheerfully pursued by the robot. Our recently-launched project CoCOMaps aims to make robots better at…