CMLabs and IIIM joins ECHORD++ project CoCoMaps
 A joint proposal by CMLabs and IIIM for the project CoCoMaps has been accepted by the ECHORD++ EU consortium for funding starting from September 2016.
A joint proposal by CMLabs and IIIM for the project CoCoMaps has been accepted by the ECHORD++ EU consortium for funding starting from September 2016.
The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform.
Today the CoCoMaps project officially launched! We are very exited to set off on this journey after months of preparation. The aim of the project is to endow robots with the skills to communicate with humans in real time using natural dialogue. If successful these improved communicational skills of the robots will enable much more sophisticated…
The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
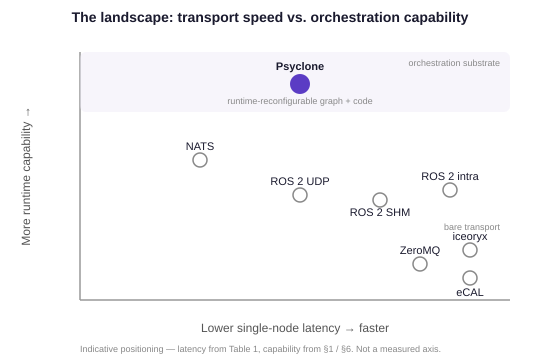
A rigorous single-node latency benchmark of Psyclone AIOS against NATS, ROS 2, iceoryx, eCAL and ZeroMQ – competitive default speed, the tightest tails measured, and the runtime-reconfiguration capabilities that set it apart.
In most typical dialogue, humans use turntaking naturally – one person waits for a natural break in the other person’s dialogue to start speaking or answering the other. Computers and robots, however, are not great at this – generally, they are actually very bad, as we have all experienced when calling a phone-based automatic speech…
Preparation of our robots is now in full swing to get them up and running for our first demo. The on-board cameras all need to run at the same time which we have been testing as well as getting the robots to communicate through the CCMCatalog. The first trial run went pretty well but afterwards…