CoCoMaps invited to exhibit at Hannover Messe 2017
 The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform.
The CoCoMaps project has been invited to exhibit our technology at the Hannover Messe 2017 in Germany. We will be showcasing our turn-taking technology running on the Psyclone 2 platform.
Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems.
The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers. Share:LinkedInXEmail Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems. Download PsycloneExplore Psyclone AIOSTalk to us More from CMLabsPsyclone 2.2.0: LLM Connections in CMSDKPsyclone…
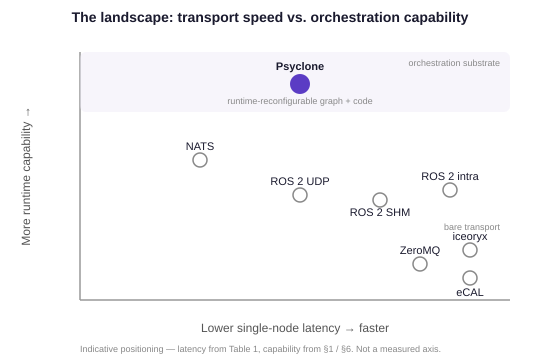
A rigorous single-node latency benchmark of Psyclone AIOS against NATS, ROS 2, iceoryx, eCAL and ZeroMQ – competitive default speed, the tightest tails measured, and the runtime-reconfiguration capabilities that set it apart.
It is our pleasure to launch a new and updated web site for Communicative Machines! Here you can follow up on all the latest news, events and developments within CMLabs. Happy browsing! Share:LinkedInXEmail Published by CMLabs. Communicative Machines builds Psyclone AIOS, an open-source orchestration runtime for sub-millisecond, crash-resistant, self-reconfiguring AI systems. Download PsycloneExplore Psyclone AIOSTalk to us…
Ever tried conversing with a robot on the other end of a telephone customer service line? Now try adding a slight delay due to indeterminism and prepare for a frustrating interruption followed by a back and forth between incorrect options, cheerfully pursued by the robot. Our recently-launched project CoCOMaps aims to make robots better at…
Demo 1 produced a lot of data and we are working our way through it now. Preliminary figures suggest that the CCMCatalog enabled the robots to collaborate far more efficiently when working together and that the robots were able to detect and track humans in the scene. Stay tuned for more results… Share:LinkedInXEmail Published…
We now have turn-taking for two participants (one robot and one human) up and running on the Psyclone 2 platform. We use Nuance for speech recognition and speech generation and can handle interruptions and long pauses. Now we just need to work on starting and ending the conversation 🙂 Share:LinkedInXEmail Published by CMLabs. Communicative Machines…