Demo 3 Video and Report
The video and the report for Demo 3 are now available to see.
The video and the report for Demo 3 are now available to see.
It is our pleasure to launch a new and updated web site for Communicative Machines! Here you can follow up on all the latest news, events and developments within CMLabs. Happy browsing!
Psyclone 2.0 already supports user authored native C++ modules running in a mixed Windows/Linux cluster environment. Now we have added native Python 2.7 and 3.5 support so our users can create either inline or separate modules written entirely in Python. As part of the CoCoMaps project we are now integrating with ROS (Robot Operating System)…
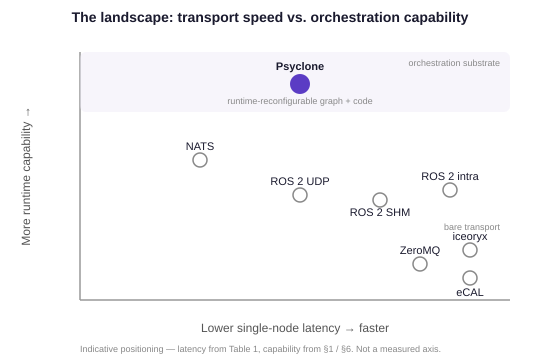
A rigorous single-node latency benchmark of Psyclone AIOS against NATS, ROS 2, iceoryx, eCAL and ZeroMQ – competitive default speed, the tightest tails measured, and the runtime-reconfiguration capabilities that set it apart.
Psyclone 2.0.2 has been released which includes a number of performance updates and improved network stability. Please visit the Download page to grab either the new binary builds or the Open Source version. We have now also finally released the first version of the full Psyclone Platform System documentation as well as the detailed CMSDK…
Demo 1 produced a lot of data and we are working our way through it now. Preliminary figures suggest that the CCMCatalog enabled the robots to collaborate far more efficiently when working together and that the robots were able to detect and track humans in the scene. Stay tuned for more results…
We now have turn-taking for two participants (one robot and one human) up and running on the Psyclone 2 platform. We use Nuance for speech recognition and speech generation and can handle interruptions and long pauses. Now we just need to work on starting and ending the conversation 🙂