CoCoMaps at CES 2017
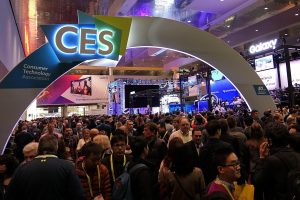 The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
The CoCoMaps team is networking at CES 2017 in Las Vegas, meeting up with a number of potential vendors, partners and customers.
The CCMCatalog is almost done and can handle the sharing and negotiation of observations and tasks between the two robots. Face detection has gone in and the new body and legs detector is being tested now. Basic navigation is working now and we are working on the operator interface in the PsyProbe web interface.
Psyclone 2.0 already supports user authored native C++ modules running in a mixed Windows/Linux cluster environment. Now we have added native Python 2.7 and 3.5 support so our users can create either inline or separate modules written entirely in Python. As part of the CoCoMaps project we are now integrating with ROS (Robot Operating System)…
We have completed Demo 2 of the project and the report and video are almost ready for publication. The robots behaved very well and worked together nicely to complete the tasks. They start up searching for humans to speak to (like in Demo 1) and once a human has been found one of the robots…
Simple robots operate through a perception-action cycle, or loop, which allows them to make decisions and form a response based on the information they receive on each cycle. Adding layers in a robot’s perception-action cycle enables it to “think outside the loop”, supporting parallel information processing on different levels simultaneously, thus making it generally more…
Later this year we plan to release version 2.0 of the Psyclone platform. It is a complete rewrite of Psyclone 1.5 with all the old features intact and with massive performance improvements, merging of discrete and streaming data messaging, introduction of drumbeat signals for simulations and a completely new web interface, PsyProbe 2.0. You can…
The CoCoMaps project has now been completed and all the deliverables and milestones have been met. We have produced the final project report which is available here. You can also still catch the project videos and all the reports on this page. We thank the ECHORD++ project and the EU for their support without which…